Dextre
Also known as Special Purpose Dexterous Manipulator, SPDM, Special Purpose Dextrous Manipulator
n., workcell. MDA Space, Canada, 2008. In service.
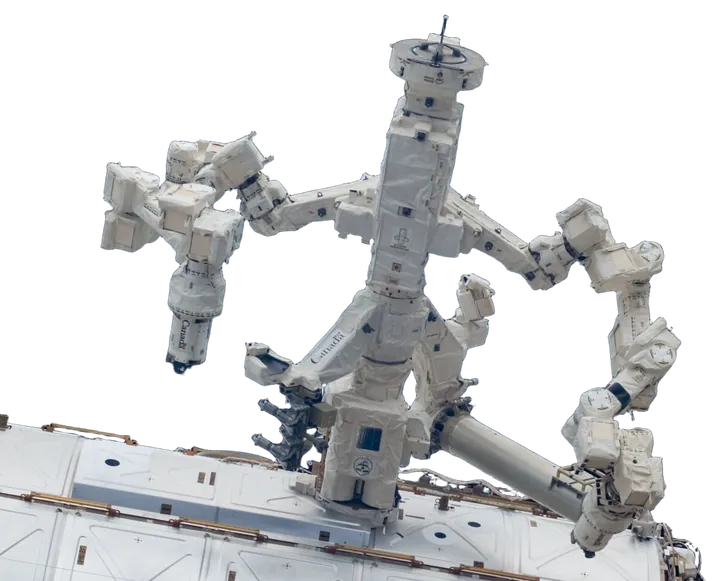
Robotic telemanipulator with two arms on the International Space Station, built by MDA Space to handle repair work that would otherwise call for spacewalking astronauts.
| Maker | MDA Space |
|---|---|
| Country | Canada |
| First shown | 2008 |
| Status | In service |
| Height | 3.67 m |
| Mass | 1710 kg |
| Width | 2.37 m |
Of note
- Launched on 11 March 2008 on mission STS-123
- Part of the station's Mobile Servicing System
- Stands 3.67 m tall with a mass of 1710 kg
Sources
- Wikipedia, Dextre, en.wikipedia.org
- Wikidata, Dextre (Q904690), wikidata.org
- Cited source, asc-csa.gc.ca, asc-csa.gc.ca
- Cited source, asc-csa.gc.ca, asc-csa.gc.ca
- Cited source, nasa.gov, nasa.gov
- Cited source, nasa.gov, nasa.gov
- Picture, background removed: Dextre attached to Harmony during Expedition 17 (ISS017-E-009056, cropped) by NASA, Public domain, via Wikimedia Commons

Cite this entry
“Dextre.” Robot Dictionary, robotdictionary.com/dextre/. Revised 8 November 2026.
Entry added 8 November 2026, revised 8 November 2026. Suggest a correction or edit this entry.