#
8A4 class ROUV n., underwater robot. Shenyang Institute of Automation, China. Remotely operated underwater vehicle of the work class type, developed by China's Shenyang Institute of Automation for jobs ranging from oil platform servicing to salvage and rescue.
A
ABISMO n., underwater robot. Japan Agency for Marine-Earth Science and Technology, Japan. Japanese deep sea remotely operated vehicle built by the Japan Agency for Marine-Earth Science and Technology as the replacement for Kaikō, which was lost in 2003. In service.
Aquanaut n., underwater robot. Nauticus Robotics, United States. Underwater robot that cruises as an autonomous vehicle and then opens into a two armed remotely operated vehicle at its work site.
Argo n., marine robot. Woods Hole Oceanographic Institution. Uncrewed camera sled towed deep underwater, developed by Robert Ballard at Woods Hole's Deep Submergence Laboratory, that helped find the wreck of the Titanic in 1985.
Autonomous Benthic Explorer n., underwater robot. United States, 1996. Autonomous underwater vehicle operated by the Woods Hole Oceanographic Institution that surveyed broad stretches of seabed down to 4500 m until its loss at sea in 2010. Lost.
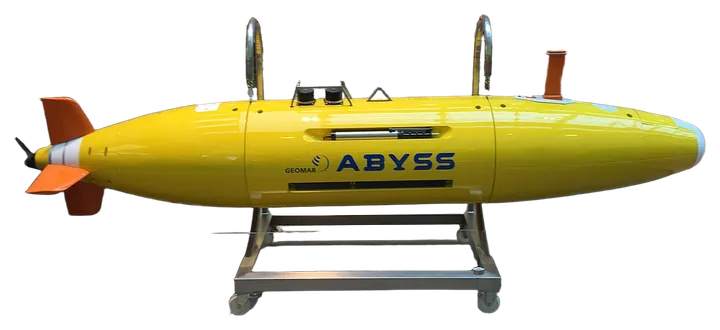
AUV ABYSS n., underwater robot. Hydroid, United States, 2008. REMUS 6000 autonomous underwater vehicle built by Hydroid in 2008 and owned by GEOMAR, used to map the deep seabed and gather data from the water column. In service.
AUV-150 n., underwater robot. Central Mechanical Engineering Research Institute, India. Indian autonomous underwater vehicle under development by scientists at the Central Mechanical Engineering Research Institute in Durgapur, West Bengal, with support from IIT Kharagpur. In development.
B
Benthic Rover II n., marine robot. Monterey Bay Aquarium Research Institute, United States, 2015. Autonomous tracked seafloor rover that has monitored carbon cycling on the abyssal plain off California for years at a time. In service.
Bluefin-21 n., underwater robot. Bluefin Robotics, United States. Autonomous underwater vehicle from Bluefin Robotics for defence, commercial and scientific tasks, best known for its part in the 2014 hunt for Malaysia Airlines Flight 370.
BlueROV2 n., underwater robot. Blue Robotics, United States, 2016. Modular underwater remotely operated vehicle from the American company Blue Robotics, offered at low cost and run on open source control software. In production.
Boaty McBoatface n., underwater robot. National Oceanography Centre, United Kingdom, 2017. British autonomous underwater vehicle belonging to the Autosub Long Range class, run by the National Oceanography Centre for scientific research. In service.
C
COTSBot n., underwater robot. Queensland University of Technology, Australia. Small autonomous underwater vehicle from Queensland University of Technology that finds crown of thorns starfish on the Great Barrier Reef and kills them by injection. Research platform.
D
DEPTHX n., underwater robot. Stone Aerospace, United States. Autonomous underwater vehicle that Stone Aerospace of Austin, Texas, built to map and sample flooded sinkholes in northern Mexico, as a NASA funded step toward exploring Europa. Research platform.
Discovery n., underwater robot. Specialist Machine Development, United Kingdom. Remotely operated underwater vehicle built in Britain by Specialist Machine Development for use in China; little has been published about it.
E
Echo Ranger n., underwater robot. Boeing, United States. Autonomous underwater vehicle from the American company Boeing, built to operate at sea without anyone aboard.
Echo Seeker n., underwater robot. Boeing. Autonomous underwater vehicle built by Boeing, a robotic submersible that travels beneath the sea surface without a crew or remote pilot.
Echo Voyager n., underwater robot. Boeing. Autonomous underwater vehicle built by Boeing, an uncrewed submersible that navigates and works below the surface on its own.
Eelume n., underwater robot. Eelume AS. Autonomous underwater vehicle under development by the company Eelume AS, intended to operate beneath the sea without a crew. In development.
ENDURANCE n., underwater robot. Stone Aerospace. Autonomous underwater vehicle built by Stone Aerospace to chart Antarctic underwater terrain in 3D, recording its geochemistry and biology.
Épaulard n., underwater robot. France, 1979. Uncrewed underwater vehicle from France, operated remotely and belonging to the Ifremer institute, for work beneath the sea surface.
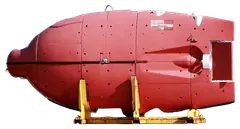
Eureka n., marine robot. Impossible Metals, United States. Autonomous underwater vehicle from Impossible Metals that hovers above the seabed and uses a robotic arm and vision to pick polymetallic nodules one at a time.
Explorer AUV n., underwater robot. China, 1994. Chinese autonomous underwater vehicle that entered service in November 1994 and supplied the experience behind many later Chinese designs.
F
Fleetzero n., marine robot. Fleetzero, United States. Electric cargo vessels designed to run with remote supervision instead of a full crew.
G
Global Explorer ROV n., underwater robot. Deep Sea Systems International, United States. Deep water remotely operated vehicle made by Chris Nicholson of Deep Sea Systems International and used on research and survey dives deeper than 2,700 m.
H
Hadal ARV n., underwater robot. Shenyang Institute of Automation, China. Chinese hybrid unmanned underwater vehicle from the Shenyang Institute of Automation that can work either autonomously or under remote control, much like Nereus.
J
Jason n., underwater robot. Woods Hole Oceanographic Institution, 1988. Two body remotely operated vehicle built and operated by the National Deep Submergence Laboratory of the Woods Hole Oceanographic Institution, first launched in 1988. In service.
Jason Jr. n., underwater robot. Woods Hole Oceanographic Institution. Small remotely operated vehicle built by the Deep Submergence Laboratory at Woods Hole Oceanographic Institution as a test model for its bigger successor, Jason. Retired.
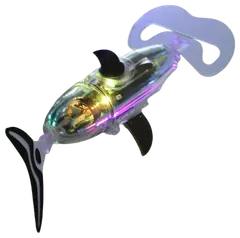
Jessiko n., marine robot. Robotswim, France. Small autonomous robotic fish, 22 cm long, created by the French startup Robotswim, based in Palaiseau near Paris.
K
Kaikō n., underwater robot. JAMSTEC, Japan, 1993. Japanese deep sea remotely operated vehicle built by JAMSTEC that reached the floor of the Challenger Deep and was lost during a typhoon in 2003. Lost.
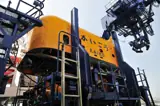
Kaşif n., underwater robot. Turkey. Remotely operated underwater vehicle from Turkey that supports subsea drilling by carrying out a range of tasks during offshore gas exploration.
M
Maya AUV n., underwater robot. National Institute of Oceanography, India. Indian autonomous underwater vehicle built by the marine instrumentation team at the National Institute of Oceanography.
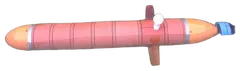
Mayflower Autonomous Ship n., marine robot. ProMare and IBM, United Kingdom, 2020. Solar powered research trimaran that sails without a crew, steered by an onboard AI captain.
Mini Rover ROV n., underwater robot. Deep Sea Systems International, United States, 1983. Tethered underwater remotely operated vehicle created by Chris Nicholson of Deep Sea Systems International, introduced in 1983 as the first compact and inexpensive ROV.
N
Nereus n., underwater robot. Woods Hole Oceanographic Institution, United States, 2009. Hybrid uncrewed underwater vehicle from the Woods Hole Oceanographic Institution, made for research at full ocean depth, which reached the floor of the Challenger Deep in 2009.
O
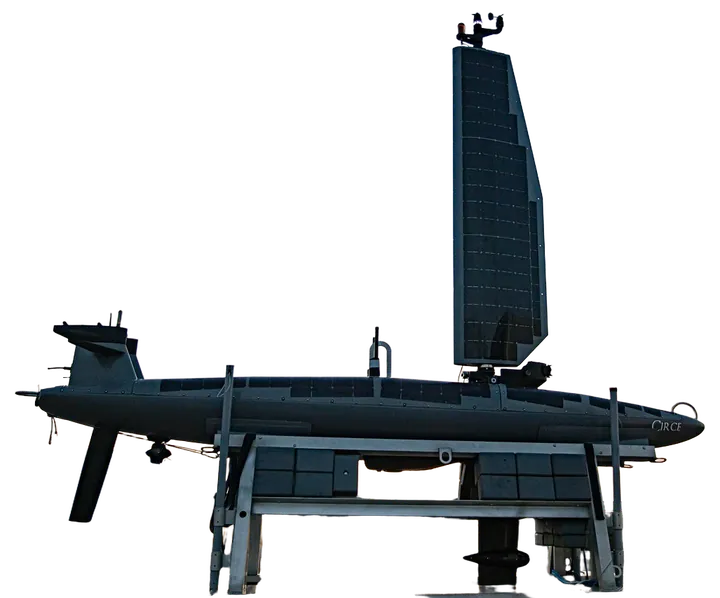
Ocean Aero Triton n., underwater robot. Ocean Aero, United States. Autonomous vessel from the American company Ocean Aero that can travel both on the surface and underwater, propelled by solar and wind power for long missions. In production.
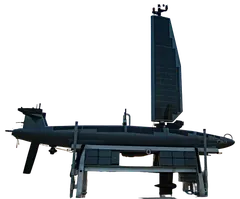
OceanOne n., underwater robot. Stanford University, United States, 2016. Humanoid diving robot from Stanford with two arms, stereo eyes and thrusters, steered by a pilot who feels what its hands touch through haptic controls. Research platform.
R
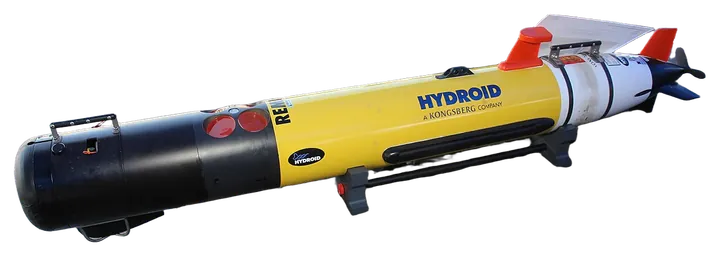
REMUS n., underwater robot. Woods Hole Oceanographic Institution. Family of low cost autonomous underwater vehicles from the Woods Hole Oceanographic Institution, later built by Hydroid, used for seabed mapping, surveys and naval mine countermeasures. In production.
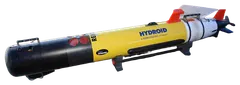
Roboat n., marine robot. Amsterdam Institute for Advanced Metropolitan Solutions, Netherlands, 2016. Autonomous research boats developed by MIT, Delft University of Technology and Wageningen University for moving people and goods on Amsterdam's canals, where prototypes were tested. Research platform.
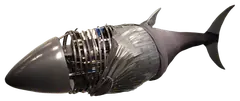
Roboshark n., marine robot. United Kingdom, 2003. Robotic shark built by Andrew Sneath in 2003 and fitted with a camera to film whale sharks, bull sharks and great white sharks for the BBC.
RoboTuna n., marine robot. Massachusetts Institute of Technology, United States, 1993. Line of robotic fish that a team at the Massachusetts Institute of Technology built while investigating designs for autonomous underwater vehicles. Retired.
ROPOS n., underwater robot. International Submarine Engineering, Canada. Remotely operated underwater vehicle used mainly for science, built in Vancouver by International Submarine Engineering and later purchased by the Canadian federal government. In service.
ROV KIEL 6000 n., underwater robot. Schilling Robotics, United States. Electrically powered remotely operated vehicle made by Schilling Robotics of California and owned by Germany's GEOMAR, used for scientific work down to 6,000 m. In service.
ROV Odysseus 6K n., underwater robot. Pelagic Research Services, United States. Deep diving remotely operated vehicle from Pelagic Research Services of South Wellfleet, Massachusetts, rated to work as deep as 6,000 m of seawater. In service.
ROV PHOCA n., underwater robot. Sub-Atlantic, United Kingdom. Compact remotely operated underwater vehicle built by Sub-Atlantic in Aberdeen and owned by the GEOMAR ocean research centre in Kiel, able to dive to 3000 m. In service.
ROV SuBastian n., underwater robot. Tethered remotely operated underwater vehicle that the Schmidt Ocean Institute deploys from its research ship RV Falkor (too) for deep sea science, capable of reaching 4,500 m. In service.
RU-27 n., underwater robot. United States, 2009. Experimental American underwater glider run by ocean scientists at Rutgers University that in 2009 made the first robotic crossing of the Atlantic beneath the surface.
S
Saildrone Explorer n., marine robot. Saildrone, United States. Wind and solar powered uncrewed sailing vessel that gathers ocean and weather data on missions lasting months. In production.
Sawfish harvester n., underwater robot. Triton Logging Inc.. Submersible logging robot made by Triton Logging that uses large pincers and a chainsaw to fell trees flooded by dams and float them to the surface.
Scout n., marine robot. United States, 2013. Robotic boat built by students from Tiverton, Rhode Island, in an attempt to become the first autonomous craft to cross the Atlantic Ocean.
Sea Dragon class ROV n., underwater robot. China. Series of Chinese work class remotely operated vehicles for oil platform servicing, salvage and rescue, all derived from the original Sea Dragon. In service.
SeaBotix ROV n., underwater robot. Teledyne Marine. Series of underwater remotely operated vehicles marketed by Teledyne Marine under the SeaBotix brand name.
Seaglider n., underwater robot. University of Washington, United States. Long endurance underwater glider developed at the University of Washington that profiles ocean temperature and salinity for months at a time. In production.
SeaPerch n., underwater robot. MIT Sea Grant College Program, United States, 2003. Educational kit and curriculum in which school students build a basic remotely operated underwater vehicle from PVC pipe and other everyday materials.
Sentry n., underwater robot. Woods Hole Oceanographic Institution. Autonomous underwater vehicle made by the Woods Hole Oceanographic Institution that carries instruments for collecting samples, images and readings in the deep sea. In service.
SJT class ROUV n., underwater robot. Shenyang Institute of Automation and Shanghai Jiao Tong University, China. Chinese family of remotely operated underwater vehicles created as a joint project of the Shenyang Institute of Automation and the underwater engineering institute of Shanghai Jiao Tong University.
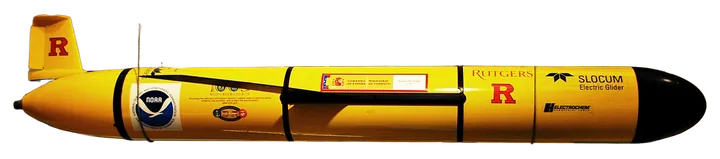
Slocum glider n., underwater robot. Teledyne Webb Research, United States. Buoyancy driven underwater glider that travels for weeks by changing its displacement, named after the sailor Joshua Slocum. In production.
SPURV n., underwater robot. University of Washington Applied Physics Laboratory, United States, 1957. Autonomous underwater research vehicle that the University of Washington's Applied Physics Laboratory built in 1957, becoming the US Navy's first AUV. Retired.
Submerged Dragon 1 n., underwater robot. China. Chinese autonomous underwater vehicle, an uncrewed craft that operates beneath the sea surface under its own onboard control.
U
Ultra Trencher 1 n., marine robot. Submersible trenching robot that buries undersea pipelines by cutting trenches in the seabed, described as the largest submersible robot in the world.
USV Maxlimer n., marine robot. United Kingdom. Uncrewed surface vessel run by the British firm SEA-KIT International that can work semi autonomously or under remote control, and won the Shell Ocean Discovery X Prize. In service.
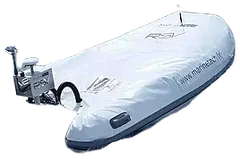
USV RSV n., marine robot. Marine Tech SAS. Unmanned surface vessel developed since 2008 by the founders of the company Marine Tech SAS. In development.
V
Vaimos n., marine robot. IFREMER and École nationale supérieure de techniques avancées Bretagne, France. French autonomous sailing boat carrying onboard instruments for measuring the ocean surface, developed by IFREMER and ENSTA Bretagne.
VideoRay ROVs n., underwater robot. VideoRay. Family of inspection class underwater remotely operated vehicles, each run from a control unit about the size of a suitcase and tethered by copper or fiber optic cable.
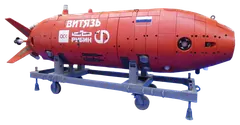
Vityaz-D n., underwater robot. Russia. Russian fully autonomous deep submergence vehicle built to reach full ocean depth, with a mass of 5650 kg.
W
Wave Glider n., marine robot. Liquid Robotics, United States. Ocean surface robot whose submerged wing converts the motion of waves into forward thrust, with solar panels for its instruments. In production.