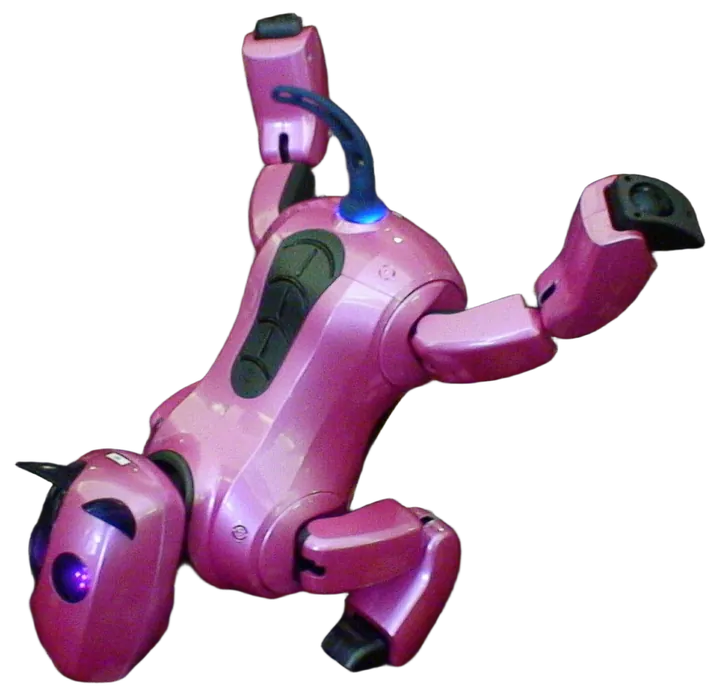
A
aibo ERS-1000 n., quadruped. Sony, Japan, 2018. Sony's revival of its robot dog, a twenty two axis home companion with camera based recognition and cloud connected behaviour. Discontinued.
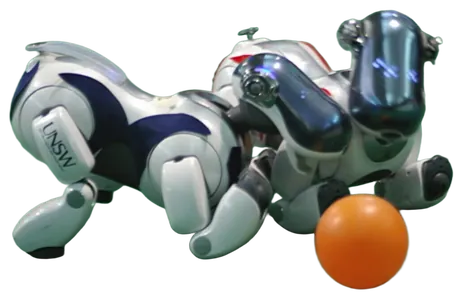
AIBO ERS-110 n., quadruped. Sony, Japan, 1999. Sony's first consumer robot dog, an eighteen joint autonomous quadruped sold as an entertainment pet rather than a research machine. Discontinued.
AIBO ERS-7 n., quadruped. Sony, 2003. Consumer entertainment robot in Sony's AIBO series, released in 2003 as the first model the company explicitly presented as a dog. Discontinued.
Aliengo n., quadruped. Unitree, China, 2019. The research quadruped that carried Unitree into universities worldwide. Retired.
AlphaDog n., quadruped. WEILAN, China, 2021. Chinese quadruped platform marketed for education, security and delivery work, launched with claims of unusually high running speed. In production.
ALPHRED 2 n., quadruped. UCLA Robotics and Mechanisms Laboratory, United States, 2019. Radially symmetric four limbed robot from UCLA that walks in any direction, uses two limbs as arms and can roll on its feet. Research platform.
ANYmal n., quadruped. ANYbotics, Switzerland, 2016. The industrial inspection quadruped patrolling offshore platforms and plants, offered in explosion proof form. In production.
ANYmal B n., quadruped. ANYbotics, Switzerland, 2016. First ANYmal generation, a sealed electric quadruped with torque controlled joints sold to research groups and early industrial pilots. Research platform.
ANYmal C n., quadruped. ANYbotics, Switzerland, 2019. Industrial version of ANYmal, packaged for autonomous inspection rounds in power plants, chemical works and offshore facilities. In service.
ANYmal D n., quadruped. ANYbotics, Switzerland, 2021. Current ANYbotics inspection quadruped, a fifty kilogram sealed machine that walks industrial plants on its own and returns to dock. In production.
ANYmal X n., quadruped. ANYbotics, Switzerland, 2023. The explosion proof ANYmal certified for oil, gas and chemical plants. In production.
Arachno-Bot n., legged robot. Fraunhofer Institute of Manufacturing Engineering and Automation, Germany, 2011. Eight legged spider inspired robot developed in 2011 at the Fraunhofer Institute of Manufacturing Engineering and Automation in Stuttgart to survey areas too dangerous for people. Research platform.
B
B2-W n., quadruped. Unitree, China, 2024. A wheeled variant of the B2 that skates stairs and slopes on powered hubs. In production.
Banryu n., quadruped. Sanyo, Japan. Robot product model developed in Japan and manufactured by the electronics company Sanyo.
BDX droids n., legged robot. Walt Disney Imagineering, United States, 2023. Child sized two legged droid characters from Disney that walk, wobble and react with cartoon like personality, trained in simulation with reinforcement learning.
Bex n., quadruped. Kawasaki, Japan, 2022. A rideable robot ibex that carries a person on its back and kneels on wheels. Announced, not yet in service.
BigDog n., quadruped. Boston Dynamics, United States, 2005. The gasoline engined pack mule whose recovery from a kick announced the legged robot age. Retired.
BionicKangaroo n., quadruped. Festo. Kangaroo shaped jumping robot from Festo that, like the animal, recovers energy from each hop and puts it into the next. Research platform.
BISAM n., quadruped. FZI Forschungszentrum Informatik, Germany, 1997. Mammal like four legged walking machine from Karlsruhe, built to study adaptive gait control with an articulated trunk. Retired.
Bittle n., quadruped. Petoi, United States, 2020. Palm sized programmable robot dog kit with nine powered joints, sold as an education platform for coding and robotics classes. In production.
C
Cheetah n., quadruped. Boston Dynamics, United States, 2012. Tethered hydraulic quadruped built for DARPA that set the land speed record for a legged robot on a laboratory treadmill. Retired.
Cheetah-cub n., quadruped. EPFL Biorobotics Laboratory, Switzerland, 2013. Cat sized compliant quadruped from EPFL that was the fastest small four legged robot of its time relative to body size. Research platform.
CORLEO n., quadruped. Kawasaki, Japan, 2025. A hydrogen powered rideable quadruped concept steered by the rider's body. Announced, not yet in service.
CyberDog n., quadruped. Xiaomi, China, 2021. Xiaomi's first quadruped, released as a limited run of one thousand units for developers at 9,999 yuan. Discontinued.
CyberDog 2 n., quadruped. Xiaomi, China, 2023. A doberman sized successor that learns tricks from demonstration. In production.
G
Genghis n., legged robot. MIT. Six legged walking robot resembling an insect, built by Rodney Brooks at MIT and associated with his reactive subsumption architecture for robot behaviour. Research platform.
Genibo n., quadruped. Dasarobot, South Korea, 2006. Korean entertainment robot dog styled as a bull terrier, sold as a home pet with voice command control. Discontinued.
Go2-W n., quadruped. Unitree, China, 2024. The consumer Go2 on wheels, rolling where legs would waste energy. In production.
H
HOUND n., quadruped. KAIST, South Korea, 2023. A sprinting quadruped holding a Guinness 100 metre record for its class. Research platform.
HyQ n., quadruped. Italian Institute of Technology, Italy, 2010. Hydraulically actuated quadruped from the Italian Institute of Technology used to study dynamic legged locomotion. Research platform.
HyQReal n., quadruped. Italian Institute of Technology, Italy, 2019. A hydraulic heavyweight that once towed a three tonne aircraft. Research platform.
I
i-Cybie n., quadruped. Silverlit Toys Manufactory, Hong Kong, 2000. Robotic toy dog produced in Hong Kong by Silverlit Toys from 2000 to 2006 that reacted to sound, touch, motion and spoken commands. Discontinued.
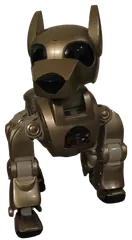
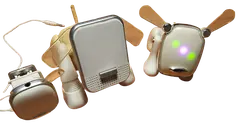
iDog n., quadruped. Sega Fave, Japan, 2005. Robot dog toy from Sega that flashes its lights and dances along to music played into it from an iPod or other MP3 player.
J
Jueying Lite3 n., quadruped. DEEP Robotics, China, 2022. A parkour capable research quadruped in the consumer price class. In production.
Jueying X20 n., quadruped. DEEP Robotics, China, 2021. A payload quadruped hauling sensors through disaster training rubble. In production.
Jueying X30 n., quadruped. DEEP Robotics, China, 2023. An all weather inspection quadruped working power stations and tunnels. In production.
K
KUMO-I n., quadruped. Tokyo Institute of Technology, Japan, 1976. Spider inspired research quadruped by Shigeo Hirose and Yoji Umetani, the first machine in the long walking robot programme at Tokyo Institute of Technology. Retired.
L
Laikago n., quadruped. Unitree Robotics, China, 2017. First commercial quadruped from Unitree and the machine that opened the low cost Chinese robot dog market. Discontinued.
LAURON n., legged robot. FZI Forschungszentrum Informatik, Germany, 1994. Six legged walking robot modelled on the stick insect Carausius morosus, developed over several generations by the German research centre FZI Forschungszentrum Informatik. Research platform.
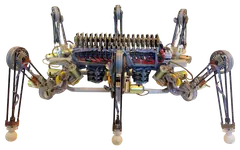
LittleDog n., quadruped. Boston Dynamics, United States, 2005. Small electric quadruped supplied to university teams as the shared hardware of the DARPA Learning Locomotion programme. Retired.
Lynx n., quadruped. DEEP Robotics, China, 2024. A wheel legged all terrain machine that skates, walks and climbs. In production.
M
Max n., quadruped. Tencent Robotics X, China, 2021. Wheel legged quadruped from Tencent's robotics laboratory that switches between walking on four legs and rolling on wheels. Research platform.
Mini Cheetah n., quadruped. MIT Biomimetic Robotics Laboratory, United States, 2019. Nine kilogram electric quadruped built from modular actuators, the first four legged robot shown performing a backflip. Research platform.
Mini Pupper n., quadruped. MangDang, China, 2021. A ROS native open source desktop quadruped crowdfunded by hobbyists. In production.
Mini Pupper 2 n., quadruped. MangDang, Hong Kong, 2022. Small open source quadruped kit built around a Raspberry Pi and ROS 2, aimed at students learning navigation and mapping. In production.
Minitaur n., quadruped. Ghost Robotics, United States, 2016. A springy direct drive quadruped that climbed fences and opened doors on legs alone. Retired.
MIT Cheetah 2 n., quadruped. MIT Biomimetic Robotics Laboratory, United States, 2014. Electric bounding quadruped that ran untethered on grass and jumped hurdles, built to show motors could match hydraulics. Retired.
MIT Cheetah 3 n., quadruped. MIT Biomimetic Robotics Laboratory, United States, 2018. Forty kilogram electric quadruped that climbed cluttered stairs and jumped onto tables using only proprioception, with no cameras. Research platform.
MIT Quadruped n., quadruped. MIT Leg Laboratory, United States, 1984. Hydraulic running quadruped from Marc Raibert's MIT Leg Laboratory that trotted, paced and bounded using a decomposed balance controller. Retired.
Momaro n., legged robot. University of Bonn, Germany, 2015. Centaur like robot from the University of Bonn with four legs ending in wheels and two arms, built for the DARPA Robotics Challenge. Retired.
P
Phony Pony n., quadruped. University of Southern California, United States, 1966. Early electrically driven quadruped from USC, generally recognised as the first walking machine in the United States controlled entirely by a computer. Retired.
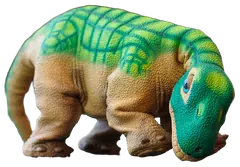
Pleo n., quadruped. Innvo Labs. Animatronic toy dinosaur modelled on a baby Camarasaurus about a week old, designed by Caleb Chung, who helped create the Furby, and first sold by Ugobe.
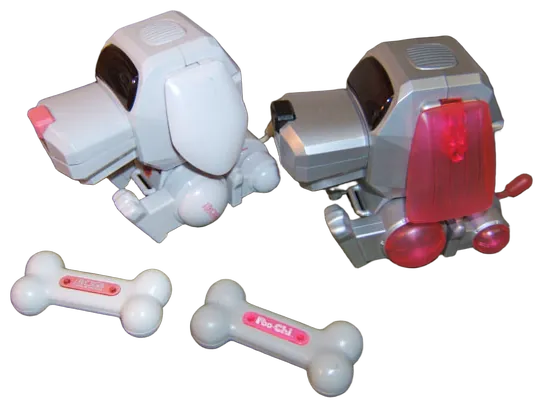
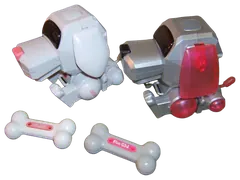
Poo-Chi n., quadruped. Sega Toys, Japan, 2000. Low cost robotic puppy that walked on four legs, sold worldwide as a cheap toy alternative to expensive entertainment robots. Discontinued.
R
RaiBo n., quadruped. KAIST, South Korea, 2022. Learning controlled quadruped from KAIST able to run across a sandy beach, terrain that defeats most legged robots. Research platform.
Raptor n., quadruped. KAIST, South Korea, 2014. Two legged running robot designed at KAIST in 2014, modelled on the velociraptor and able to run at up to 46 km/h. Research platform.
RBQ-10 n., quadruped. Rainbow Robotics, South Korea, 2023. A Korean industrial quadruped for patrol and payload work. In production.
RBQ-3 n., quadruped. Rainbow Robotics, South Korea. Electric quadruped from the Korean maker of the HUBO humanoids, sold as a platform for research and field inspection. In production.
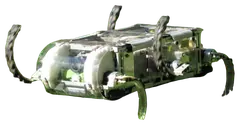
RHex n., legged robot. Boston Dynamics, United States, 2001. Six legged robot with passive stability whose compliant legs are each driven by one actuator, developed with US university partners and built by Boston Dynamics. Research platform.
RIVR n., quadruped. RIVR (Swiss-Mile), Switzerland, 2023. A wheel legged delivery quadruped that stands upright to hand over parcels; trained end to end in simulation. In pilot deployments.
Roboquad n., quadruped. WowWee, 2007. Four legged toy robot from WowWee, designed by Mark Tilden and announced at CES in January 2007, looking partly like a spider and partly like a dog.
Roboraptor n., quadruped. WowWee, 2004. Walking toy robot sold by WowWee, invented in 2004 by Mark Tilden and Michael Bellantoni, that can roam on its own using three lifelike gaits.
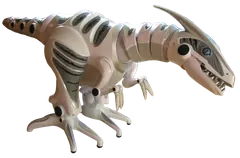
Roboreptile n., quadruped. WowWee, 2006. Four legged reptilian toy robot from WowWee that uses infrared and sound sensors to explore on its own while steering clear of obstacles.
RoboSimian n., legged robot. NASA Jet Propulsion Laboratory, United States, 2013. Four limbed ape like robot from NASA's Jet Propulsion Laboratory built for the DARPA Robotics Challenge, where it finished fifth in the 2015 finals. Retired.
Robug III n., quadruped. University of Portsmouth, United Kingdom. Mobile robot shaped like a spider, developed at the University of Portsmouth in the United Kingdom.
RunBot n., quadruped. 2005. Miniature two legged walking robot that uses reflexes triggered by foot contact sensors instead of a central pattern generator to produce its gait. Research platform.
S
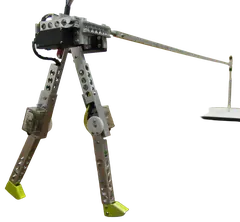
Scout II n., quadruped. McGill University, Canada, 2000. Minimalist running quadruped from McGill with only one actuated joint per leg and passive springy lower legs. Retired.
Solo 12 n., quadruped. Open Dynamic Robot Initiative, Germany, 2020. Open hardware torque controlled quadruped weighing a few kilograms, designed so any laboratory could build one from printed parts. Research platform.
Solo 8 n., quadruped. Open Dynamic Robot Initiative, Germany, 2019. A fully open hardware research quadruped reproducible on a lab budget. Research platform.
SpaceBok n., quadruped. ETH Zurich Robotic Systems Lab, Switzerland, 2018. Jumping quadruped built by Swiss students to study legged movement in low gravity for lunar and asteroid exploration. Retired.
Sparko n., quadruped. Westinghouse, United States, 1940. The world's fair robot dog who barked, begged and sat beside Elektro. Retired.
Spirit 40 n., quadruped. Ghost Robotics, United States, 2020. Small electric quadruped from Ghost Robotics sold for research, swarm experiments and reconnaissance in confined spaces. In production.
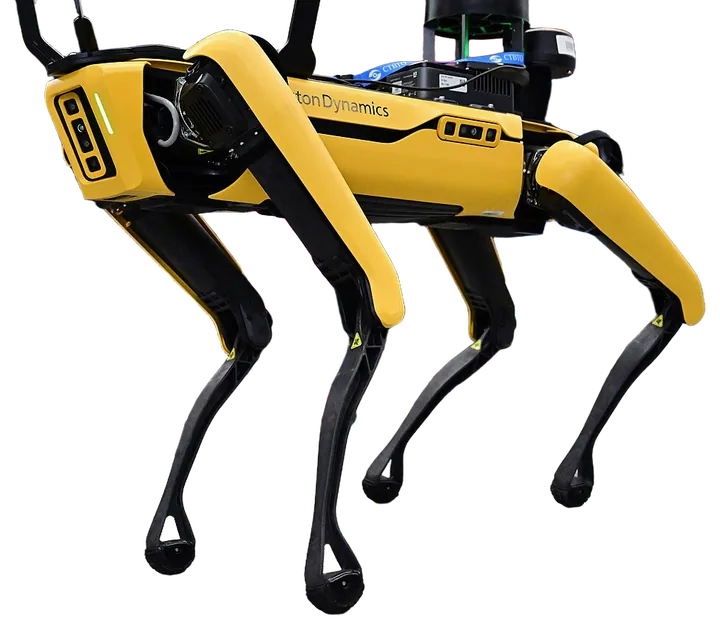
Spot n., quadruped. Boston Dynamics, United States, 2016. Electric inspection quadruped, the machine that turned legged robots into an off the shelf industrial product. In production.
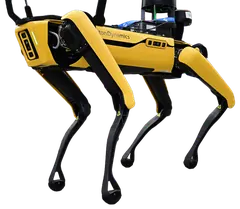
Spot Classic n., quadruped. Boston Dynamics, United States, 2015. The hydraulic middleweight between BigDog and today's Spot. Retired.
Stanford Doggo n., quadruped. Stanford Student Robotics, United States, 2019. Open source quasi direct drive quadruped built by students for a few thousand dollars that set a vertical jumping record. Retired.
Stanford Pupper n., quadruped. Stanford Student Robotics, United States, 2020. Open source servo driven quadruped derived from Stanford Doggo and designed as a teaching kit for legged robotics courses. Research platform.
StarlETH n., quadruped. ETH Zurich, Switzerland, 2012. Series elastic electric quadruped from ETH Zurich that showed compliant actuation could give small legged robots dynamic gaits. Retired.
Stiquito n., legged robot. 1992. Small, low cost six legged walking robot used since 1992 by universities, high schools and hobbyists.
T
Tekken-II n., quadruped. University of Electro-Communications, Japan, 2002. Small electric quadruped used to test neural oscillator gait control with reflexes on irregular outdoor ground. Retired.
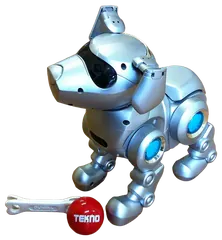
Tekno the Robotic Puppy n., quadruped. 2000. Electronic robot dog toy launched in late 2000 that became a worldwide hit, with sales passing 40 million in its first four years.
TITAN VIII n., quadruped. Tokyo Institute of Technology, Japan, 1996. Compact wire driven quadruped from the Hirose laboratory, built as a general purpose walking platform for research and teaching. Retired.
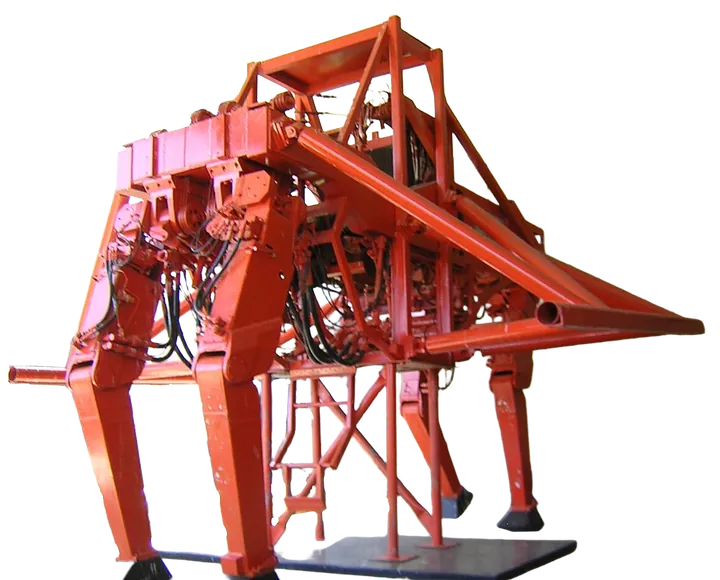
TITAN XI n., quadruped. Tokyo Institute of Technology, Japan, 2004. Seven tonne hydraulic quadruped built to drill anchor holes on steep slopes, among the largest walking machines ever completed. Retired.
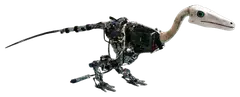
Troody n., quadruped. United States, 1995. Experimental robot from the United States, dating from 1995, that was designed to imitate a dinosaur.
U
Uniroo n., legged robot. United States, 1991. One legged robot built in the United States in 1991 and now exhibited at the MIT Museum. Retired.
Unitree A1 n., quadruped. Unitree Robotics, China, 2019. Twelve kilogram electric quadruped that brought dynamic legged research hardware down to a price universities could buy in quantity. Discontinued.
Unitree B2 n., quadruped. Unitree Robotics, China, 2023. Sixty kilogram industrial quadruped from Unitree rated to walk with forty kilograms of payload for more than four hours. In production.
Unitree Go1 n., quadruped. Unitree Robotics, China, 2021. Consumer priced electric quadruped that Unitree marketed as a walking companion, starting at around two thousand seven hundred dollars. Discontinued.
Unitree Go2 n., quadruped. Unitree Robotics, China, 2023. Fifteen kilogram consumer and developer quadruped with a hemispherical lidar, sold from well under two thousand US dollars. In production.
W
Walking Truck n., legged robot. General Electric, United States, 1965. Hydraulic four legged vehicle from General Electric that an operator drove by moving his own arms and legs inside a force feedback harness. Retired.
WildCat n., quadruped. Boston Dynamics, United States, 2013. Untethered petrol powered quadruped built to run fast in the open, the free running successor to the treadmill bound Cheetah. Retired.
WonderBorg n., quadruped. Bandai, 2000. Programmable six legged robot kit shaped like a beetle, released by Bandai in 2000 for use with the WonderSwan and Windows PCs.
X
XGO-Mini n., quadruped. Luwu Intelligence, China, 2021. A desktop quadruped with an arm on its back for pick and place tricks. In production.
Z
Zoomer n., quadruped. Spin Master, Canada, 2014. Interactive toy robot dog that responded to voice commands and learned tricks. Discontinued.