Walking Truck
Also known as GE Quadruped, Cybernetic Walking Machine
n., legged robot. General Electric, United States, 1965. Retired.
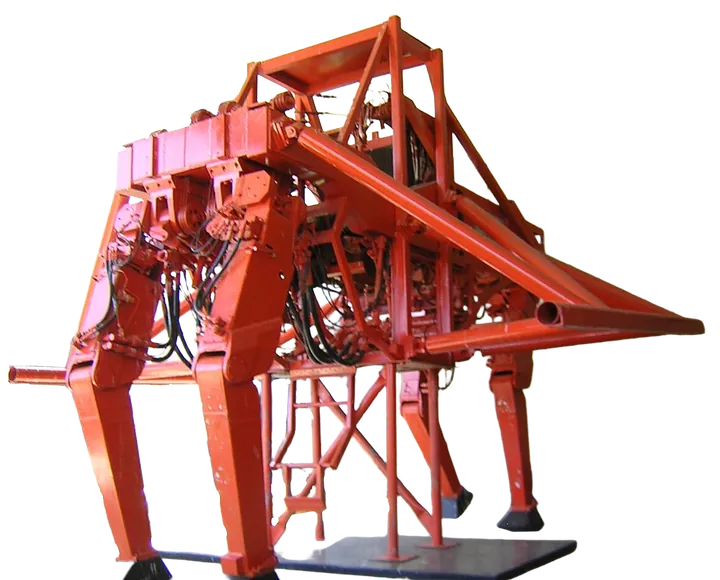
Hydraulic four legged vehicle from General Electric that an operator drove by moving his own arms and legs inside a force feedback harness.
| Maker | General Electric |
|---|---|
| Country | United States |
| First shown | 1965 |
| Status | Retired |
| Height | 3.35 m |
| Mass | 1360 kg |
| Top speed | 2.2 m/s (7.9 km/h) |
| Degrees of freedom | 12 |
| Actuation | Hydraulic cylinders, three powered joints per leg |
| Power | Onboard internal combustion engine driving hydraulic pumps |
| Autonomy | None, direct human force feedback teleoperation |
| Length | 3530.6 mm |
| Width | 1066.8 mm |
Built for the US Army by Ralph Mosher at General Electric, the Walking Truck was a rideable quadruped meant to carry loads over ground that wheels could not cross. Each leg had three hydraulically powered joints, and the driver commanded them through a master slave linkage that fed contact forces back to his own hands and feet. Operators could walk the machine, step over obstacles and lift heavy objects with a leg, but the control scheme was so tiring that the project ended after trials.
Of note
- Built under the US Army Cybernetic Anthropomorphous Machine programme
- Could lift loads of several hundred kilograms with a single leg
- Preserved at the US Army Transportation Museum at Fort Eustis
Sources
- General Electric website, ge.com
- Wikipedia, Walking Truck, en.wikipedia.org
- Wikidata, General Electric Quadruped Transporter (Q1611602), wikidata.org
- General Electric website, ge.com
- Picture, background removed: WalkingMachine USArmyTransportationMuseum DSCN7543 by Larry Pieniazek, Lar (commons) or User:Lar (en:wp primary), CC BY-SA 4.0, via Wikimedia Commons

Cite this entry
“Walking Truck.” Robot Dictionary, robotdictionary.com/ge-walking-truck/. Revised 8 November 2026.
Entry added 14 August 2026, revised 8 November 2026. Suggest a correction or edit this entry.