#
5DX n., workcell. Agilent Technologies, United States. Automated inspection robot, made by Hewlett Packard and later Agilent Technologies, that took 3D radiographic images of assembled circuit boards to check the solder. Discontinued.
A
Armatron n., robot arm. Tomy, 1984. Joystick controlled toy robot arm from Tomy, sold through Radio Shack stores in the United States from 1984, with no automatic functions.
Aseon Pod n., workcell. Aseon Labs, United States. Robotic micro depot that charges, cleans and services self driving cars between trips.
Azalea n., workcell. Azalea Robotics Corporation, United States. Robots that load and sort checked luggage in airport baggage halls.
B
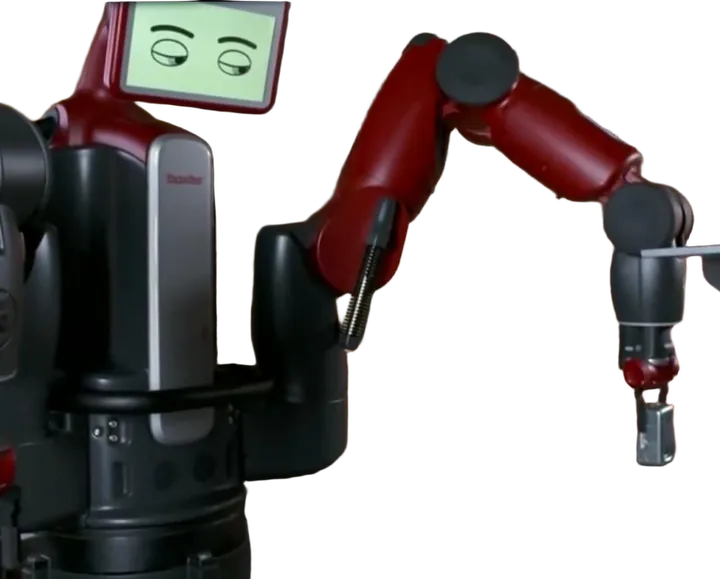
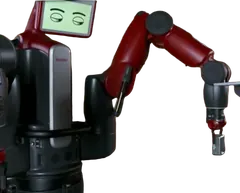
Baxter n., workcell. Rethink Robotics, United States, 2011. Two armed collaborative industrial robot from Rethink Robotics, the startup founded by Rodney Brooks, that has an animated face.
Bistrobot n., workcell. Bistrobot, United States. Automated sandwich line from a San Francisco startup that assembled orders while customers watched. Discontinued.
Blue Jay n., robot arm. Amazon Robotics, United States, 2025. Amazon workcell in which several robot arms work over one station at once, picking, stowing and consolidating items. Discontinued.
BotBuilt n., workcell. BotBuilt, United States. Robotic cells that assemble wall panels and roof trusses for house framing.
C
CA-1 n., workcell. Circus SE, Germany, 2025. Autonomous robotic cooking system introduced in 2025 by the German company Circus SE.
Cafe X n., workcell. Cafe X, United States, 2017. Robotic coffee kiosk in which an arm pulls espresso drinks ordered from a phone or touchscreen, first opened in San Francisco.
Canadarm n., robot arm. SPAR Aerospace, Canada, 1981. Family of robotic arms built by SPAR Aerospace of Canada that Space Shuttle orbiters carried to release, move and capture payloads in orbit. Retired.
Canadarm2 n., robot arm. MDA, Canada, 2001. Robotic arm of the International Space Station, built in Canada, that moves end over end between fixtures and captures visiting cargo ships. In service.
Canadarm3 n., workcell. MDA, Canada. Robotic system planned for the Gateway lunar space station, combining a large arm, a small dexterous arm and tools, built by MDA for the Canadian Space Agency. In development.
Cardinal n., robot arm. Amazon Robotics, United States, 2022. Amazon robot arm that picks parcels from a jumbled pile, reads their labels and stacks them into carts.
COBOTTA n., robot arm. Denso Wave, Japan. Portable six axis collaborative arm from Denso light enough to be carried and set up on a desk. In production.
Creator n., workcell. Creator, United States, 2018. Automated burger line that ground, cooked and assembled burgers to order at a San Francisco restaurant that opened in 2018.
CRX-10iA n., robot arm. FANUC, Japan, 2019. Lightweight collaborative arm from FANUC programmed by dragging it by hand or with a tablet interface. In production.
D
DeLaval VMS n., workcell. DeLaval, Sweden. Voluntary milking system in which a robot arm attaches the teat cups as each cow enters the stall. In production.
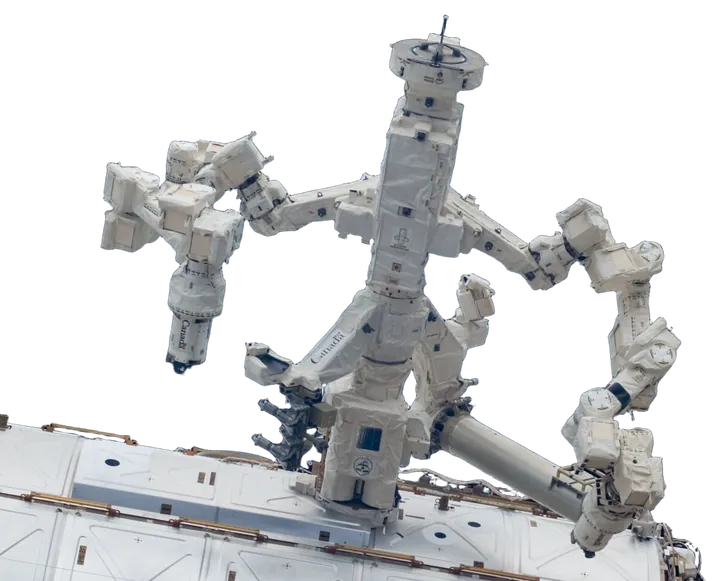
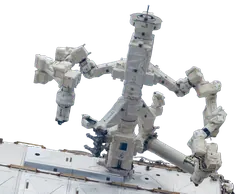
Dextre n., workcell. MDA Space, Canada, 2008. Robotic telemanipulator with two arms on the International Space Station, built by MDA Space to handle repair work that would otherwise call for spacewalking astronauts. In service.
Dobot Magician n., robot arm. Dobot, China. Small four axis desktop arm that can draw, laser engrave and 3D print, used widely in schools. In production.
duAro n., robot arm. Kawasaki Heavy Industries, Japan, 2015. Two armed SCARA style robot from Kawasaki on a wheeled base, sized to take the place of one worker on an assembly line. In production.
E
e-David n., workcell. University of Konstanz, Germany, 2009. Painting robot developed at the University of Konstanz that works out brushstrokes from a source image and paints it onto canvas. Research platform.
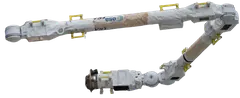
European Robotic Arm n., robot arm. Airbus Defence and Space, Netherlands, 2021. Robotic arm for the Russian segment of the International Space Station, launched attached to the Nauka module in 2021. In service.
F
FarmBot n., workcell. FarmBot, United States. Open source gantry robot that plants, waters and weeds a raised garden bed, sold as a kit. In production.
FlexPicker n., robot arm. ABB, Switzerland. High speed parallel arm robot from ABB that picks small items from conveyors, based on the delta design invented by Reymond Clavel at EPFL. In production.
Flippy n., workcell. Miso Robotics, United States, 2017. Robot arm from Miso Robotics that flips burgers and runs deep fryers in fast food kitchens, first placed at CaliBurger. In production.
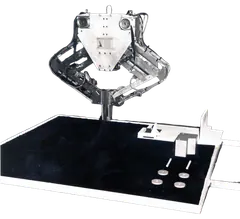
Freddy II n., workcell. Department of Machine Intelligence and Perception, 1973. Experimental robot built at the Department of Machine Intelligence and Perception and active from 1973 to 1976 as the successor to the original Freddy. Retired.
G
Gen3 n., robot arm. Kinova, Canada. Ultralight seven axis arm from Kinova used in research labs and on mobile robots. In production.
GoFa n., robot arm. ABB, Switzerland, 2021. Collaborative arm from ABB with joint torque sensing, meant to be set up by staff without robot programming experience. In production.
Grip n., workcell. Grip, Switzerland. Picking robot that removes contaminants from organic waste streams, learning from every successful and failed grasp.
H
Hedgehog n., workcell. Hedgehog, United States. Robotic growing system that automates mushroom farms.
I
InLoop n., workcell. InLoop Robotics, Germany. Robot arms that pick and pack online orders, with remote operators stepping in when a grasp fails.
IRB 6 n., robot arm. ASEA, Sweden, 1974. Early industrial arm from ASEA, the forerunner of ABB, often described as the first all electric microprocessor controlled industrial robot. Retired.
J
JACO n., robot arm. Kinova, Canada. Lightweight arm mounted on a power wheelchair so people with limited upper body mobility can eat, drink and open doors. In production.
JEMRMS n., robot arm. JAXA, Japan, 2008. Robotic arm system of the Japanese Kibo module on the International Space Station, used to move experiments onto the module's exposed platform. In service.
K
Kanguera n., robot hand. University of São Paulo, Brazil, 2007. Research robot hand from the University of São Paulo that models the kinematics of the human hand to help develop better humanlike grippers and manipulators. Research platform.
KR 1000 titan n., robot arm. KUKA, Germany, 2007. Heavy duty arm from KUKA rated for loads of about one tonne, used to move engine blocks, stone and glass. In production.
KR AGILUS n., robot arm. KUKA, Germany. Family of small, fast six axis arms from KUKA used in electronics and packaging lines. In production.
L
LBR iiwa n., robot arm. KUKA, Germany, 2013. Seven axis lightweight arm from KUKA with torque sensors in every joint, developed from DLR research arms. In production.
Lely Astronaut n., workcell. Lely, Netherlands, 1992. Milking robot from the Dutch firm Lely, in which cows walk in to be milked whenever they choose with no farmer present. In production.
LR Mate 200iD n., robot arm. FANUC, Japan. Compact six axis arm from FANUC, one of the most widely installed small industrial robots. In production.
M
M-2000iA n., robot arm. FANUC, Japan. Very large six axis arm from FANUC that can lift car bodies and other loads weighing more than two tonnes. In production.
M1013 n., robot arm. Doosan Robotics, South Korea. Collaborative arm from Doosan Robotics with torque sensors in all six joints. In production.
Meca500 n., robot arm. Mecademic, Canada. Very small six axis industrial arm from Mecademic, sized for laboratory automation and electronics assembly. In production.
Mezli n., workcell. Mezli, United States. Fully automated restaurant built into a shipping container that cooked meals for takeout and delivery. Discontinued.
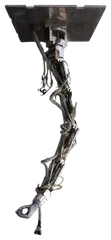
Minsky's Tentacle Arm n., robot arm. 1965. Robot arm dating from 1965, built to imitate a human arm and now exhibited at the MIT Museum. Retired.
Mobot n., workcell. Mobot, United States. Mechanical robots that tap and swipe real phones to test mobile apps where emulators fall short.
Moley Robotic Kitchen n., workcell. Moley Robotics, United Kingdom, 2015. Pair of ceiling mounted arms with dexterous hands that cook recipes recorded from human chefs. In production.
Motoman HC10 n., robot arm. Yaskawa, Japan. Collaborative arm in the Yaskawa Motoman range with hand guided teaching and pinch point protection. In production.
Multiply Labs n., workcell. Multiply Labs, United States. Cloud controlled modular robotic system that manufactures individualized drugs, a process normally done by hand.
myCobot 280 n., robot arm. Elephant Robotics, China. Palm sized six axis arm from Elephant Robotics sold for teaching and hobby projects. In production.
Mytos n., workcell. Mytos, United Kingdom. Robotic platform that turns stem cells into specific cell types such as neurons and heart cells over several weeks.
O
Odin n., robot arm. Odin Robotics, United States. Robot arms placed in small and mid sized factories for machine tending and packing, working beside existing machines and people.
Opentrons Flex n., workcell. Opentrons, United States, 2023. Larger successor to the OT-2 launched in May 2023, adding a gripper that moves labware between deck positions.
Orangewood Labs n., robot arm. Orangewood Labs, United States. San Francisco maker of low cost robot arms and the software that lets them learn new tasks.
Origami hand n., robot hand. Origami Robotics, United States. High degree of freedom direct drive robotic hand from Origami Robotics, matched to a glove like device that records human demonstrations.
OT-2 n., workcell. Opentrons, United States. Benchtop pipetting robot from Opentrons with an open source protocol library, built to bring lab automation to ordinary biology labs.
P
Panda n., robot arm. Franka Emika, Germany, 2017. Seven axis arm with torque sensing in every joint, sold at a low price and widely adopted by research laboratories. Discontinued.
Peak Robotics KX-2 n., robot arm. Peak Robotics, 2020. Collaborative selective compliance assembly robot arm (SCARA) made by Peak Robotics for automating laboratory work in the life sciences.
Proception n., robot hand. Proception Inc, United States. Dexterous robotic hand built for humanoids, aiming at fine work such as threading a needle.
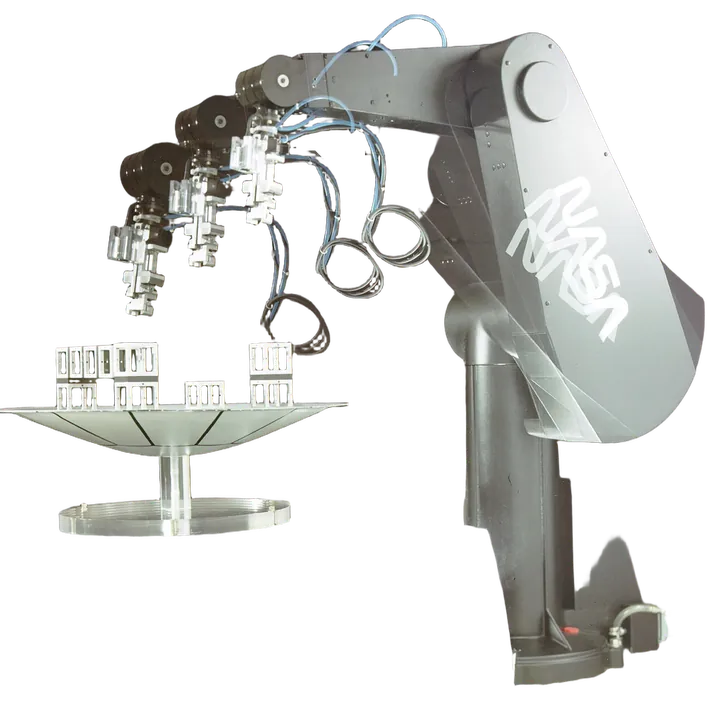
PUMA n., robot arm. Victor Scheinman, 1978. Six axis industrial robot arm that Victor Scheinman developed at Unimation, first for General Motors, from designs he had begun at Stanford University.
R
Remy n., workcell. Remy AI, United States. Robots and learned models that automate dexterous picking in online retail warehouses.
Reshape n., workcell. Reshape Biotech, Denmark. Single purpose lab robots that fill plates and photograph cultures for microbiologists.
Revise n., workcell. Revise Robotics, United States. Robotic system that tests, wipes and refurbishes used laptops for electronic waste recyclers.
RoboDock n., workcell. RoboDock, United States. Robots that plug in and check electric and autonomous vehicles at fleet depots.
RoboTire n., workcell. RoboTire, United States. Automated bay that removes and fits vehicle tires, aimed at fleet servicing. Discontinued.
RoboTurb n., workcell. Universidade Federal de Santa Catarina, Brazil, 1998. Welding robot developed at the Universidade Federal de Santa Catarina in Brazil to repair turbine blades, built as a redundant robot mounted on a flexible rail.
Rodeo n., workcell. Rodeo Robotics, United States. Robotic technician that performs oil changes at fleet depots.
S
Sally n., workcell. Chowbotics, United States. Vending machine sized robot that assembled salads and bowls from refrigerated canisters, bought by DoorDash in 2021. Discontinued.
Sawyer n., robot arm. Rethink Robotics, United States, 2015. Single armed, seven axis collaborative robot from the makers of Baxter, with a screen that shows simple facial expressions. Discontinued.
Sewbo n., workcell. Sewbo, Inc., United States. Industrial robot that carries out sewing work, invented by the American company Sewbo, Inc.
Shadow Dexterous Hand n., robot hand. Shadow Robot Company, United Kingdom. Dexterous robot hand from the Shadow Robot Company in London, built to human hand size and shape with the same full set of degrees of freedom. In production.
Shinkei n., workcell. Shinkei Systems, United States. Robot for fishing boats that uses computer vision to apply the Japanese ikejime method, which keeps fish fresher for longer.
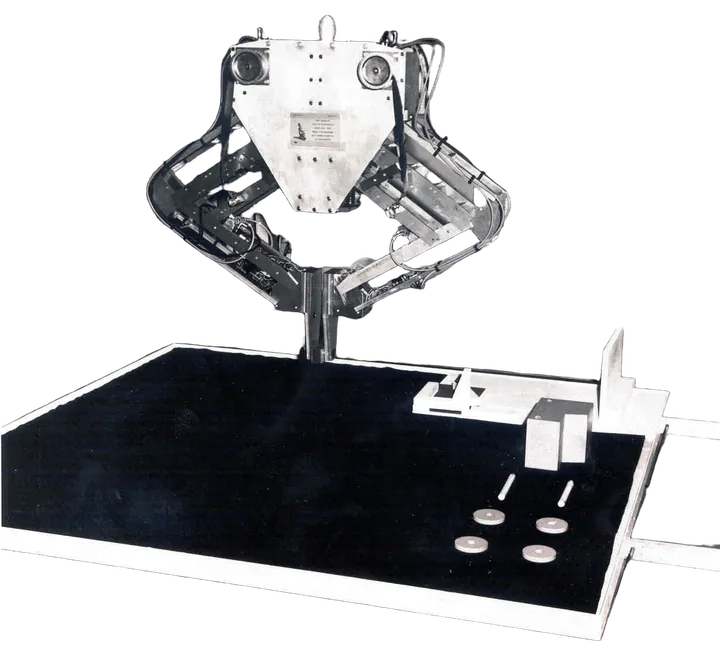
Silver Arm n., robot arm. MIT, United States, 1974. Early robot arm built by David Silver at MIT that used touch and pressure sensors to assemble small parts. Retired.
SO-101 n., robot arm. Hugging Face and TheRobotStudio, 2025. Low cost, 3D printable open source robot arm, built in leader and follower pairs for teaching robots by demonstration with the LeRobot software. In production.
Sparrow n., workcell. Amazon Robotics, United States, 2022. Robot arm from Amazon that uses computer vision and suction to pick individual products from bins in fulfilment centres. In pilot deployments.
Spyce n., workcell. Spyce, United States, 2018. Boston restaurant whose automated woks cooked grain bowls, founded by MIT graduates and bought by Sweetgreen in 2021. Retired.
Stanford arm n., robot arm. Stanford University, 1969. Early robot arm offering six degrees of freedom, created by Victor Scheinman at Stanford University in 1969 and often used as a teaching example in robotics.
SWIFTI n., robot arm. ABB, Switzerland, 2021. Small, fast arm from ABB that slows or stops when a person comes near, bridging industrial and collaborative robots. In production.
T
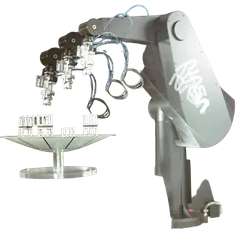
T3 n., workcell. Cincinnati Milacron, United States. Hydraulic industrial robot from Cincinnati Milacron, the first commercially available industrial robot controlled by a minicomputer. Retired.
teaBOT n., workcell. teaBOT, Canada. Robotic kiosk that blends and brews loose leaf tea to order, placed in offices and showrooms as a workplace amenity.
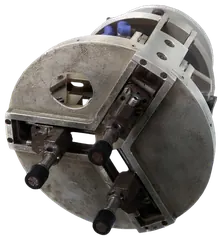
Three finger prehensile robot n., workcell. France, 1990. Gripping unit with three fingers, dating from 1990, designed to fit the end of assembly robots in the car industry and lent by the Laboratoire de robotique de Paris.
TM5 n., robot arm. Techman Robot, Taiwan. Collaborative arm from Techman Robot with a camera built into the wrist for locating parts. In production.
Transcriptic n., workcell. Transcriptic, United States. Remote controlled robotic laboratory where researchers ran life science experiments over the internet. Discontinued.
U
Ultra n., workcell. Ultra, United States. General purpose robot for repetitive industrial tasks such as packing, installed in hours without custom integration.
Unimate n., robot arm. Unimation, United States, 1961. Industrial robot regarded as the first of its kind, which went to work on a General Motors assembly line in New Jersey in 1961. Retired.
UR10e n., robot arm. Universal Robots, Denmark, 2018. Long reach e-Series arm from Universal Robots used for palletising, packaging and machine tending. In production.
UR16e n., robot arm. Universal Robots, Denmark, 2019. Heavy payload member of the Universal Robots e-Series, built for loading machines and carrying heavy tools. In production.
UR20 n., robot arm. Universal Robots, Denmark, 2022. Redesigned collaborative arm from Universal Robots with new joints, aimed at palletising and welding. In production.
UR30 n., robot arm. Universal Robots, Denmark, 2023. Compact high payload arm from Universal Robots that shares the joint design of the UR20. In production.
UR3e n., robot arm. Universal Robots, Denmark, 2018. Smallest arm of the Universal Robots e-Series, sized for benchtop assembly and screwdriving. In production.
UR5 n., robot arm. Universal Robots, Denmark, 2008. Six axis arm from Universal Robots that was among the first robots sold to work beside people without a safety cage. Discontinued.
UR5e n., robot arm. Universal Robots, Denmark, 2018. Medium sized e-Series arm from Universal Robots with a built in force and torque sensor at the tool flange. In production.
UWA Telerobot n., workcell. University of Western Australia, Australia, 1996. Remotely operated robot dating from 1996, run by the University of Western Australia's School of Mechanical and Civil Engineering.
V
Vassar n., robot arm. Vassar Robotics, United States. Gearless robot joints and arms driven by high torque transverse flux motors, built for AI research labs.
Versatran n., workcell. AMF, United States. Cylindrical coordinate industrial robot from American Machine and Foundry, one of the earliest robots put to work in a factory. Retired.
Vulcan n., robot arm. Amazon Robotics, United States, 2025. Warehouse picking robot from Amazon with force sensing grippers, described by the company as its first robot with a sense of touch. In service.
W
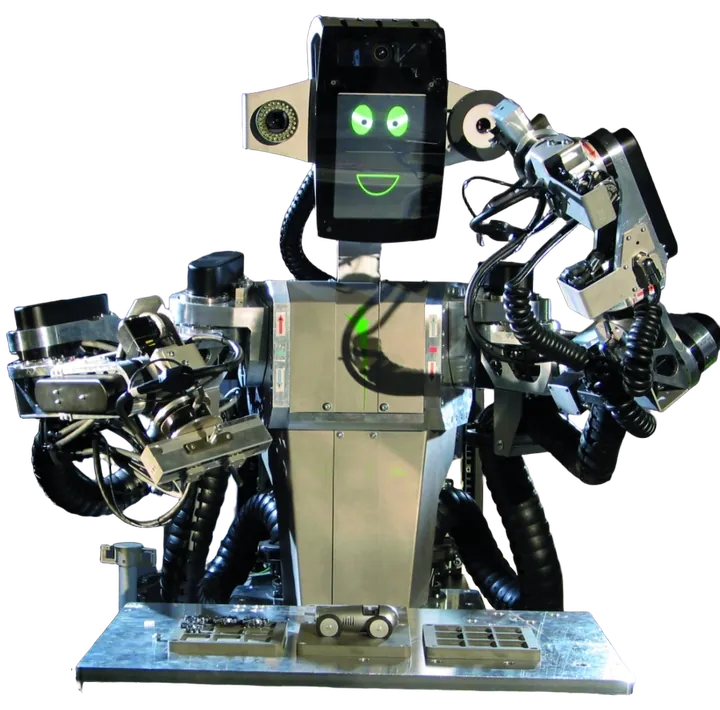
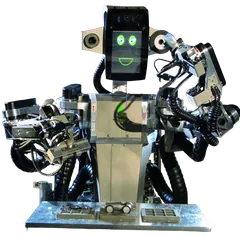
Workerbot n., workcell. pi4 robotics GmbH. Industrial robot from pi4 robotics GmbH whose movement and sensing abilities are modelled on those of a human.
X
xArm 6 n., robot arm. UFactory, China. Low cost six axis arm from UFactory popular with universities and small workshops. In production.
XR-2 n., workcell. Rhino Robotics. Educational robot manufactured by Rhino Robotics as a teaching tool for training students in robotics.
Y
YuMi n., robot arm. ABB, Switzerland, 2015. Two armed collaborative robot from ABB, padded and lightweight, built for small parts assembly beside people. In production.
Yummy Future n., workcell. Yummy Future, United States. Robotic stations that take over repetitive preparation work in restaurants and food retail.