Three finger prehensile robot
n., workcell. France, 1990.
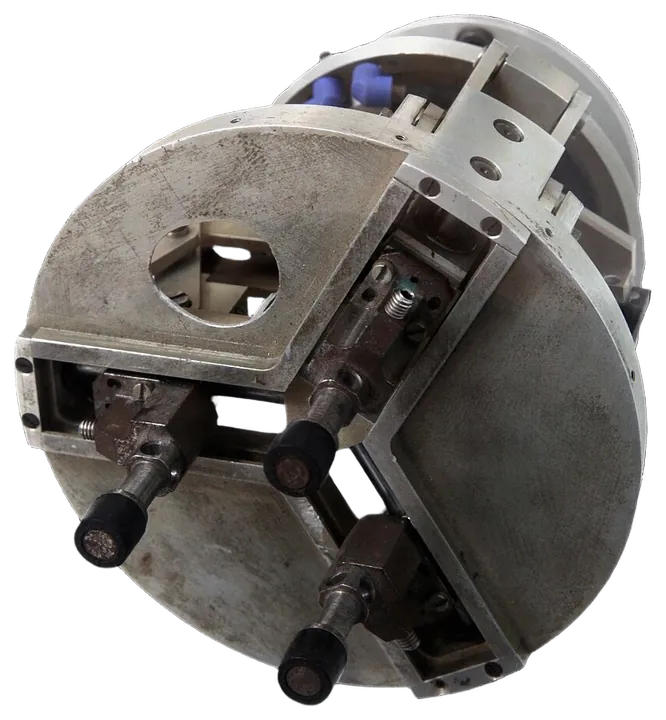
Gripping unit with three fingers, dating from 1990, designed to fit the end of assembly robots in the car industry and lent by the Laboratoire de robotique de Paris.
| Country | France |
|---|---|
| First shown | 1990 |
Sources
- Wikidata, Three-finger prehensile robot-FRE 2507 CNRS (Q54891502), wikidata.org
- Picture, background removed: Three-finger prehensile robot-FRE 2507 CNRS-IMG 5132-gradient by Rama, CC BY-SA 3.0 fr, via Wikimedia Commons

Cite this entry
“Three finger prehensile robot.” Robot Dictionary, robotdictionary.com/three-finger-prehensile-robot/. Revised 8 November 2026.
Entry added 8 November 2026, revised 8 November 2026. Suggest a correction or edit this entry.