RunBot
n., quadruped. 2005. Research platform.
Miniature two legged walking robot that uses reflexes triggered by foot contact sensors instead of a central pattern generator to produce its gait.
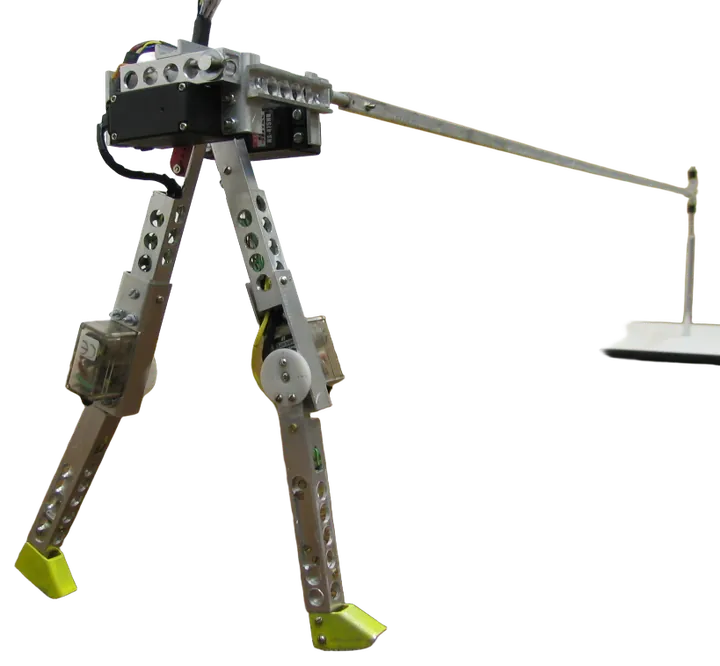
| First shown | 2005 |
|---|---|
| Status | Research platform |
Of note
- Built in 2005 by Tao Geng as part of his PhD
- Its walking speed can be improved through reinforcement learning
- Its movement draws on the work of neurophysiologist Nikolai Bernstein
Sources
- Wikipedia, RunBot, en.wikipedia.org
- Wikidata, RunBot (Q7379471), wikidata.org
- Picture, background removed: RunBot biped walking robot by Tao Geng by Berndporr, CC BY-SA 3.0, via Wikimedia Commons

Cite this entry
“RunBot.” Robot Dictionary, robotdictionary.com/runbot/. Revised 8 November 2026.
Entry added 8 November 2026, revised 8 November 2026. Suggest a correction or edit this entry.