Woods Hole Oceanographic Institution
Robots by Woods Hole Oceanographic Institution recorded in the dictionary: 6 entries, United States.
Jason n., underwater robot. Woods Hole Oceanographic Institution, 1988. Two body remotely operated vehicle built and operated by the National Deep Submergence Laboratory of the Woods Hole Oceanographic Institution, first launched in 1988. In service.
Nereus n., underwater robot. Woods Hole Oceanographic Institution, United States, 2009. Hybrid uncrewed underwater vehicle from the Woods Hole Oceanographic Institution, made for research at full ocean depth, which reached the floor of the Challenger Deep in 2009.
Argo n., marine robot. Woods Hole Oceanographic Institution. Uncrewed camera sled towed deep underwater, developed by Robert Ballard at Woods Hole's Deep Submergence Laboratory, that helped find the wreck of the Titanic in 1985.
Jason Jr. n., underwater robot. Woods Hole Oceanographic Institution. Small remotely operated vehicle built by the Deep Submergence Laboratory at Woods Hole Oceanographic Institution as a test model for its bigger successor, Jason. Retired.
REMUS n., underwater robot. Woods Hole Oceanographic Institution. Family of low cost autonomous underwater vehicles from the Woods Hole Oceanographic Institution, later built by Hydroid, used for seabed mapping, surveys and naval mine countermeasures. In production.
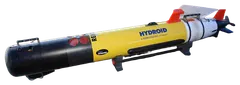
Sentry n., underwater robot. Woods Hole Oceanographic Institution. Autonomous underwater vehicle made by the Woods Hole Oceanographic Institution that carries instruments for collecting samples, images and readings in the deep sea. In service.