PrOP-M
Also known as Mars 2 rover, Mars 3 rover
n., rover. VNII Transmash and NPO Lavochkin, Soviet Union, 1971. Lost.
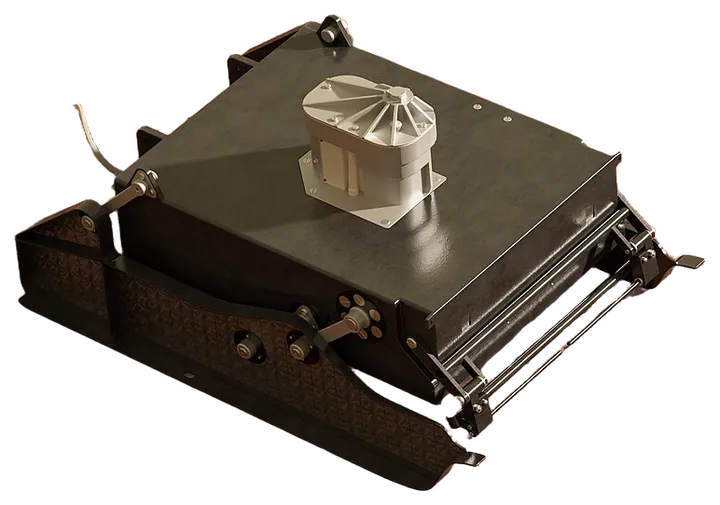
Small tethered walking rover carried by the Mars 2 and Mars 3 landers, intended to skid across the surface on twin skis.
| Maker | VNII Transmash and NPO Lavochkin |
|---|---|
| Country | Soviet Union |
| First shown | 1971 |
| Status | Lost |
| Mass | 4.5 kg |
| Actuation | Two powered skis with obstacle contact reversing |
| Power | Supplied by cable from the lander |
| Sensors | Penetrometer and gamma ray densitometer |
| Autonomy | Hardwired reflex behaviour on contact with obstacles |
Each PrOP-M was a squat box that moved on two powered skis rather than wheels, connected to its lander by a 15 metre umbilical and steered by simple contact logic that reversed and turned at obstacles. A manipulator arm was to lift the rover onto the ground, after which it would leave tracks and take penetrometer and radiation density readings within view of the lander cameras. Mars 2 crashed in November 1971 and Mars 3 stopped transmitting seconds after landing, so neither rover was ever deployed.
Of note
- First rovers sent to Mars, neither of which operated
- Tether limited operation to 15 metres from the lander
Sources
- VNII Transmash and NPO Lavochkin website, laspace.ru
- Wikipedia, PrOP-M, en.wikipedia.org
- Wikidata, Prop-M Rover (Q3197862), wikidata.org
- Picture, background removed: PrOP-M by Joris Wegner, CC BY-SA 4.0, via Wikimedia Commons

Cite this entry
“PrOP-M.” Robot Dictionary, robotdictionary.com/prop-m/. Revised 8 November 2026.
Entry added 14 August 2026, revised 8 November 2026. Suggest a correction or edit this entry.