Scarab
n., rover. Carnegie Mellon University, United States, 2008. Research platform.
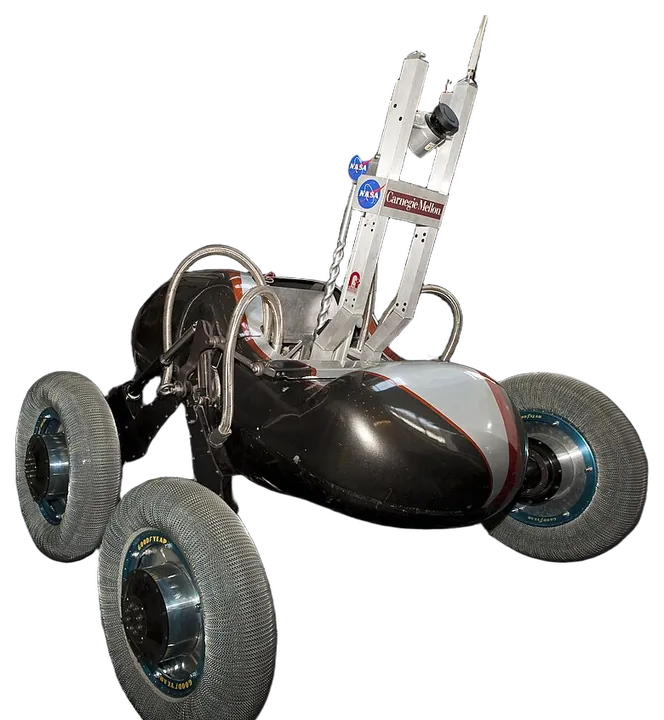
Lunar prospecting testbed rover with a body that kneels to press a drill into the ground, tested on Hawaiian volcanic soil.
| Maker | Carnegie Mellon University |
|---|---|
| Country | United States |
| First shown | 2008 |
| Status | Research platform |
| Actuation | Four wheel drive on a body that kneels and changes its footprint |
| Power | Battery electric drive designed for very low power operation |
| Sensors | Laser scanner for driving in darkness, drill and volatiles payload |
| Autonomy | Teleoperated with autonomous navigation in darkness |
Scarab was designed to prospect for water ice in permanently shadowed polar craters, so it runs on modest power and can drive in complete darkness using a laser scanner rather than cameras. Its four wheel chassis can kneel and change its footprint, using the whole vehicle mass to give the drill the reaction force needed to cut a metre into regolith. It was field tested on the slopes of Mauna Kea in Hawaii carrying NASA's RESOLVE volatiles prospecting payload, drilling and heating soil to detect water.
Of note
- Kneels so its own weight provides drilling reaction force
- Drilled with NASA's RESOLVE payload during Mauna Kea field tests
Sources
- Carnegie Mellon University website, cmu.edu
- Wikipedia, Scarab (rover), en.wikipedia.org
- Wikidata, Scarab (Q722852), wikidata.org
- Picture, background removed: Scarab Lunar Rover by Carla Cioffi, Public domain, via Wikimedia Commons

Cite this entry
“Scarab.” Robot Dictionary, robotdictionary.com/scarab/. Revised 8 November 2026.
Entry added 14 August 2026, revised 8 November 2026. Suggest a correction or edit this entry.