Robonaut 1
Also known as R1
n., humanoid. NASA Johnson Space Center with DARPA, United States, 2000. Retired.
NASA's first dexterous humanoid torso, built with DARPA to test whether a teleoperated robot could handle astronaut tools and handrails.
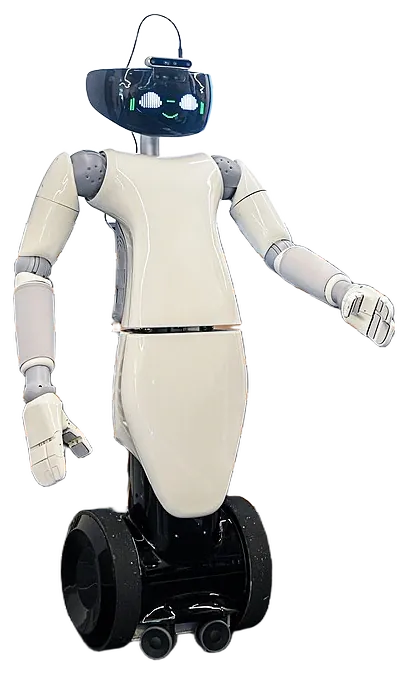
| Maker | NASA Johnson Space Center with DARPA |
|---|---|
| Country | United States |
| First shown | 2000 |
| Status | Retired |
| Actuation | Electric brushless motors with tendon driven fingers |
| Sensors | Stereo camera head with position, force and tactile sensing through the arms and hands |
| Autonomy | Telepresence operation with some autonomous grasping |
| Price | approx. $5,900 |
Robonaut 1 paired two arms and five fingered hands with a stereo camera head on a torso sized to an astronaut's work envelope, and was driven through telepresence gloves and a head mounted display. Two units, R1A and R1B, were tested with a zero gravity leg that grips handrail sockets, on a Segway based Robotic Mobility Platform in 2003 and on the four wheeled Centaur 1 chassis in 2006. None flew in space, but its hands and control software led directly to Robonaut 2.
Of note
- First NASA humanoid built to use the same tools as astronauts
- Tested on Segway based and four wheeled Centaur mobility platforms
Sources
- NASA Johnson Space Center with DARPA website, nasa.gov
- Official website, icub.iit.it
- Wikidata, R1 (Q115858991), wikidata.org
- Istituto Italiano di Tecnologia website, iit.it
- Picture, background removed: P058324-462761 by Piero Cruciatti / European Commission, CC BY 4.0, via Wikimedia Commons

See also
Cite this entry
“Robonaut 1.” Robot Dictionary, robotdictionary.com/robonaut-1/. Revised 8 November 2026.
Entry added 14 August 2026, revised 8 November 2026. Suggest a correction or edit this entry.